Service Robot Site Survey and Facility Readiness Assessment
At a glance: A robot that performs flawlessly in a showroom can fail on its first shift in a real building, and the failure is almost never the robot. It is a 780 mm doorway the unit cannot clear, a floor transition that stalls the drive wheels, a Wi-Fi dead zone behind a service corridor, or a lift that will not hand over control. Every one of those is discoverable in a 90-minute walk-through, and every one of them costs more to fix after the units arrive. This guide gives surveyors the exact measurements to take, the readiness tests to run, and a scoring sheet that turns a site visit into a defensible go or no-go decision.
Why the Site Survey Decides the Project
Procurement teams spend weeks comparing payload, battery chemistry and sensor suites, then send one person to the site for a ten-minute glance. That ordering is backwards. The robot specification tells you what a unit can do; the site survey tells you whether this building will let it. In our own deployment history the single most common cause of a stalled rollout is a physical constraint that was visible on day one and never recorded: a fire door that closes under spring tension, a carpet lip at a threshold, a mirrored lobby wall that breaks a lidar return.
A proper survey is not a sales visit. It is a measurement exercise with a pass/fail sheet, run before the purchase order, by someone who will not be blamed for the robot. Treat the output as an engineering document: raw numbers, photographs with a scale object, and a scored conclusion. If a vendor will not run this survey before you sign, that is itself a finding.
This matters commercially because a site that fails readiness after delivery does not fail cheaply. Docked units still incur the RaaS subscription, the depot and spare-unit ratio is already committed, and staff who were trained on a promise lose confidence that is slow to rebuild. For the cost arithmetic on a stalled rollout, see the downtime and OEE cost model.
The Measurements to Take and Why Each One Matters
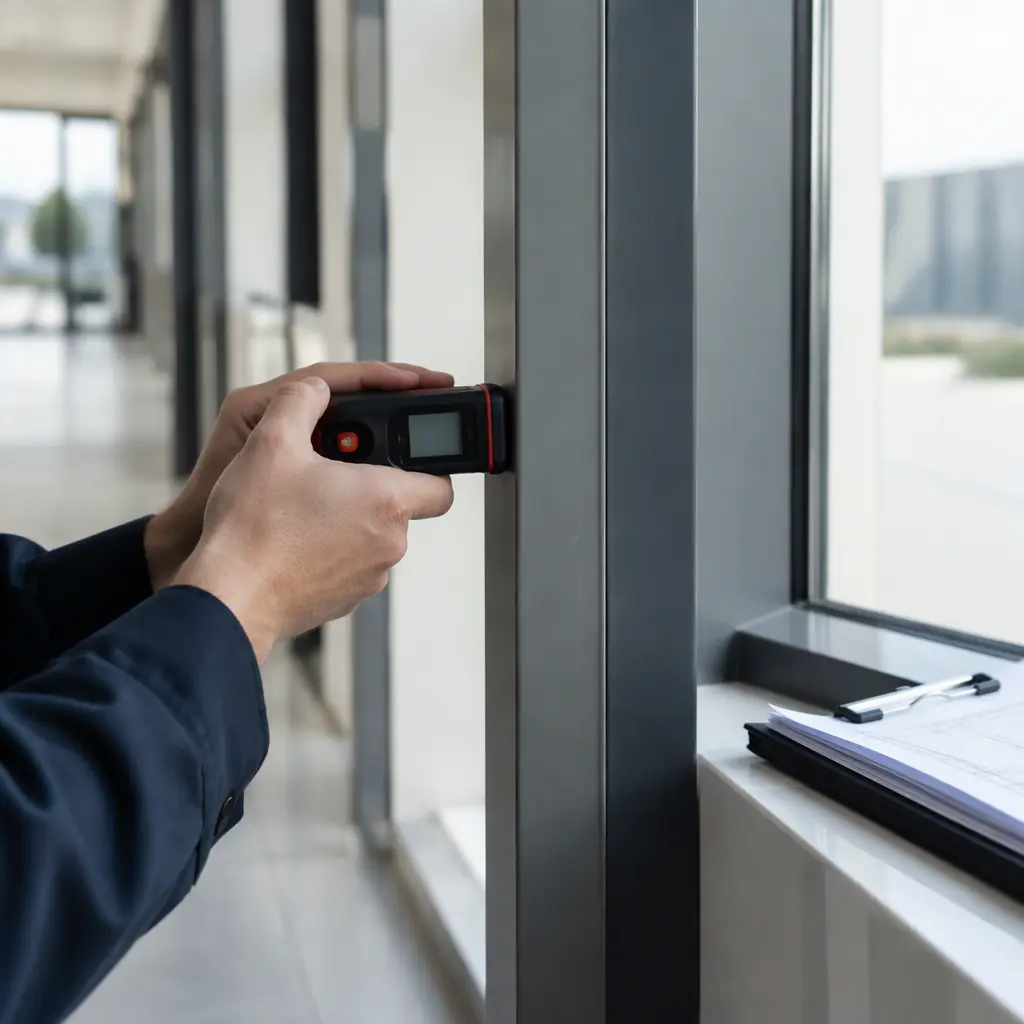
Bring a laser distance meter, a tape, a phone camera, a spirit level app and a floor-tile marking pen. Record every number against a named location, not "the main corridor". The table below is the minimum set for a floor-cleaning or delivery deployment.
| Measurement | How to take it | Typical minimum | Why it fails the robot |
|---|---|---|---|
| Clear doorway width | Narrowest point between jamb and any door-stop or closer arm | Unit width + 150 mm each side | Door closers and fire-door arms reduce clear width by 40-90 mm |
| Corridor width | Wall to wall at the tightest pinch point | Unit width + 300 mm for passing | Below this the unit must single-lane and loses throughput |
| Threshold height | Vertical step at every floor-material change | Under 15 mm ramped, under 8 mm square | Square lips over 15 mm stall a caster; 20 mm+ needs a ramp |
| Floor transition type | Photograph with a coin for scale | Hard, fixed, no loose mats | Loose anti-fatigue mats and curled vinyl defeat wheel odometry |
| Lift car depth | Inside car, door to back wall | Unit footprint + 200 mm | A delivery robot with open shelves needs turning clearance to back out |
| Ramp gradient | Rise over run, as a percentage | Under 8% for laden units | Dock ramps over 10% drain battery and risk load shift |
| Turning-circle pinch | Radius available at the tightest junction | Unit length + 100 mm | Determines whether the route needs a reverse manoeuvre |
Take each door measurement with the door in its closed resting position, not held open. A fire door on a spring closer presents a narrower clear opening than the frame suggests, and a robot running a night route will meet it closed. The same applies to the lift: measure with the doors open at their widest travel, because a partially open car door can clip a side shelf on a wide unit.
Floor and Surface Checks
Floor condition drives more real-world failures than any sensor specification. Run a three-part check:
- Slip and grip. A scrubber recovers the water it dispenses through a squeegee. On a highly polished stone floor with a tight squeegee angle, recovered water can pool momentarily and reduce traction on the drive wheel. Note any area with a visible sheen and test the unit's default water volume there before committing to a schedule.
- Surface continuity. Walk the intended route and photograph every change of material: tile to carpet, carpet to stone, stone to metal grating. Each transition is a potential stall point. Loose-lay vinyl and curling cable covers are the worst offenders.
- Obstruction density. Count freestanding obstacles per 100 m² — display stands, planters, bin stations, stanchions. A dense layout does not disqualify a robot, but it changes the route plan from sweeping passes to a tighter grid, which raises cycle time. Feed the count into the throughput calculation rather than discovering it on day one.
For buildings where the floor is also the highest-value asset, the same survey feeds the preventive schedule; the interval arithmetic is set out in the preventive maintenance schedule.
Network, Power and the Infrastructure Sign-Off
Physical readiness is half the survey. The other half is the infrastructure the robot's fleet software runs on, and it is usually owned by a different department than the one buying the robot. Capture it in the same visit so nobody discovers the gap later.
- Wi-Fi coverage. Walk the route with a phone on the facility SSID and record signal strength in dBm at the ten weakest points. Anything below −70 dBm is a candidate dead zone for teleoperation and telemetry. Robots can navigate offline, but a robot that cannot be remotely supervised during an incident will be parked. The full IT checklist is in the Wi-Fi and network connectivity guide.
- Charging point availability. Confirm a cabled supply at the planned dock, sized for the fleet, not the first unit. The electrical arithmetic is in the fleet charging infrastructure plan.
- Lift and door integration. Establish who controls the lift interface and whether a handover protocol already exists. Multi-floor routes live or die on this; see multi-floor deployment navigation layers.
- Security and data. Identify the network the fleet controller will sit on, and whether the security team will accept it. Flag the review early rather than at commissioning.
The Readiness Scoring Sheet
Turn the raw measurements into a single decision. Score each dimension pass, conditional or fail, and set the rule that any fail blocks the order until resolved. This converts an informal site visit into a document both sides can sign.
| Dimension | Pass | Conditional | Fail |
|---|---|---|---|
| Doorways and corridors | All clear widths above minimum | 1-2 pinch points, ramps or route changes fixable | Core route physically impassable |
| Floors and thresholds | Continuous, fixed, under threshold limits | Isolated lips needing ramps | Widespread loose surfaces or steps over 20 mm |
| Vertical transport | Lift handover agreed or single floor | Interface in progress with a named owner | No agreement and no owner |
| Network | SSID covers route above −70 dBm | 1-2 dead zones with a remediable fix | No usable network on the route |
| Power | Dock supply sized for the fleet | Upgrade scheduled before delivery | No supply available at any viable dock |
| Stakeholder sign-off | Facilities, IT and security all engaged | One function not yet consulted | Security rejects the fleet controller outright |
Weight the sheet to your own risk: a single-floor site can ignore vertical transport entirely, while a hospital or a multi-tenant tower should treat the lift interface as a hard gate. The point is not the specific weights; it is that the decision is made on recorded numbers before the order, not on optimism after it.
What a Good Survey Deliverable Looks Like
The survey is finished when you can hand over a single document containing: a marked-up floor plan with the proposed route; a photograph log with scale references for every doorway, transition and dock; a raw measurements table; the filled scoring sheet; and a short list of remediation items with an owner and a target date for each. If the sheet says conditional, no purchase order should be raised until every remediation item is closed.
Run the survey in daylight and, if the site will operate at night, run it once after dark as well. Lighting levels, reflective floors under artificial light, and closed fire doors change the picture materially. A survey run only at 11 a.m. in a bright lobby tells you nothing about the 2 a.m. reality the robot will actually work in.
Continue Reading
- structuring a robot pilot programme before full rollout
- scoring the go or no-go decision at pilot exit
- the IT sign-off checklist for fleet connectivity
- navigation layers and vertical constraints in multi-floor sites
- sizing charging infrastructure and power for a fleet
- the cost of a stalled deployment measured in OEE
Get a Quote
Tell us about your site and workload and we will size the fleet, the accessories and the service plan around your actual operation. Request a quote or email sales@aomanbot.com.
Get a Quote
Tell us about your space and workload, we reply within 24 hours.