Computer Vision & Perception
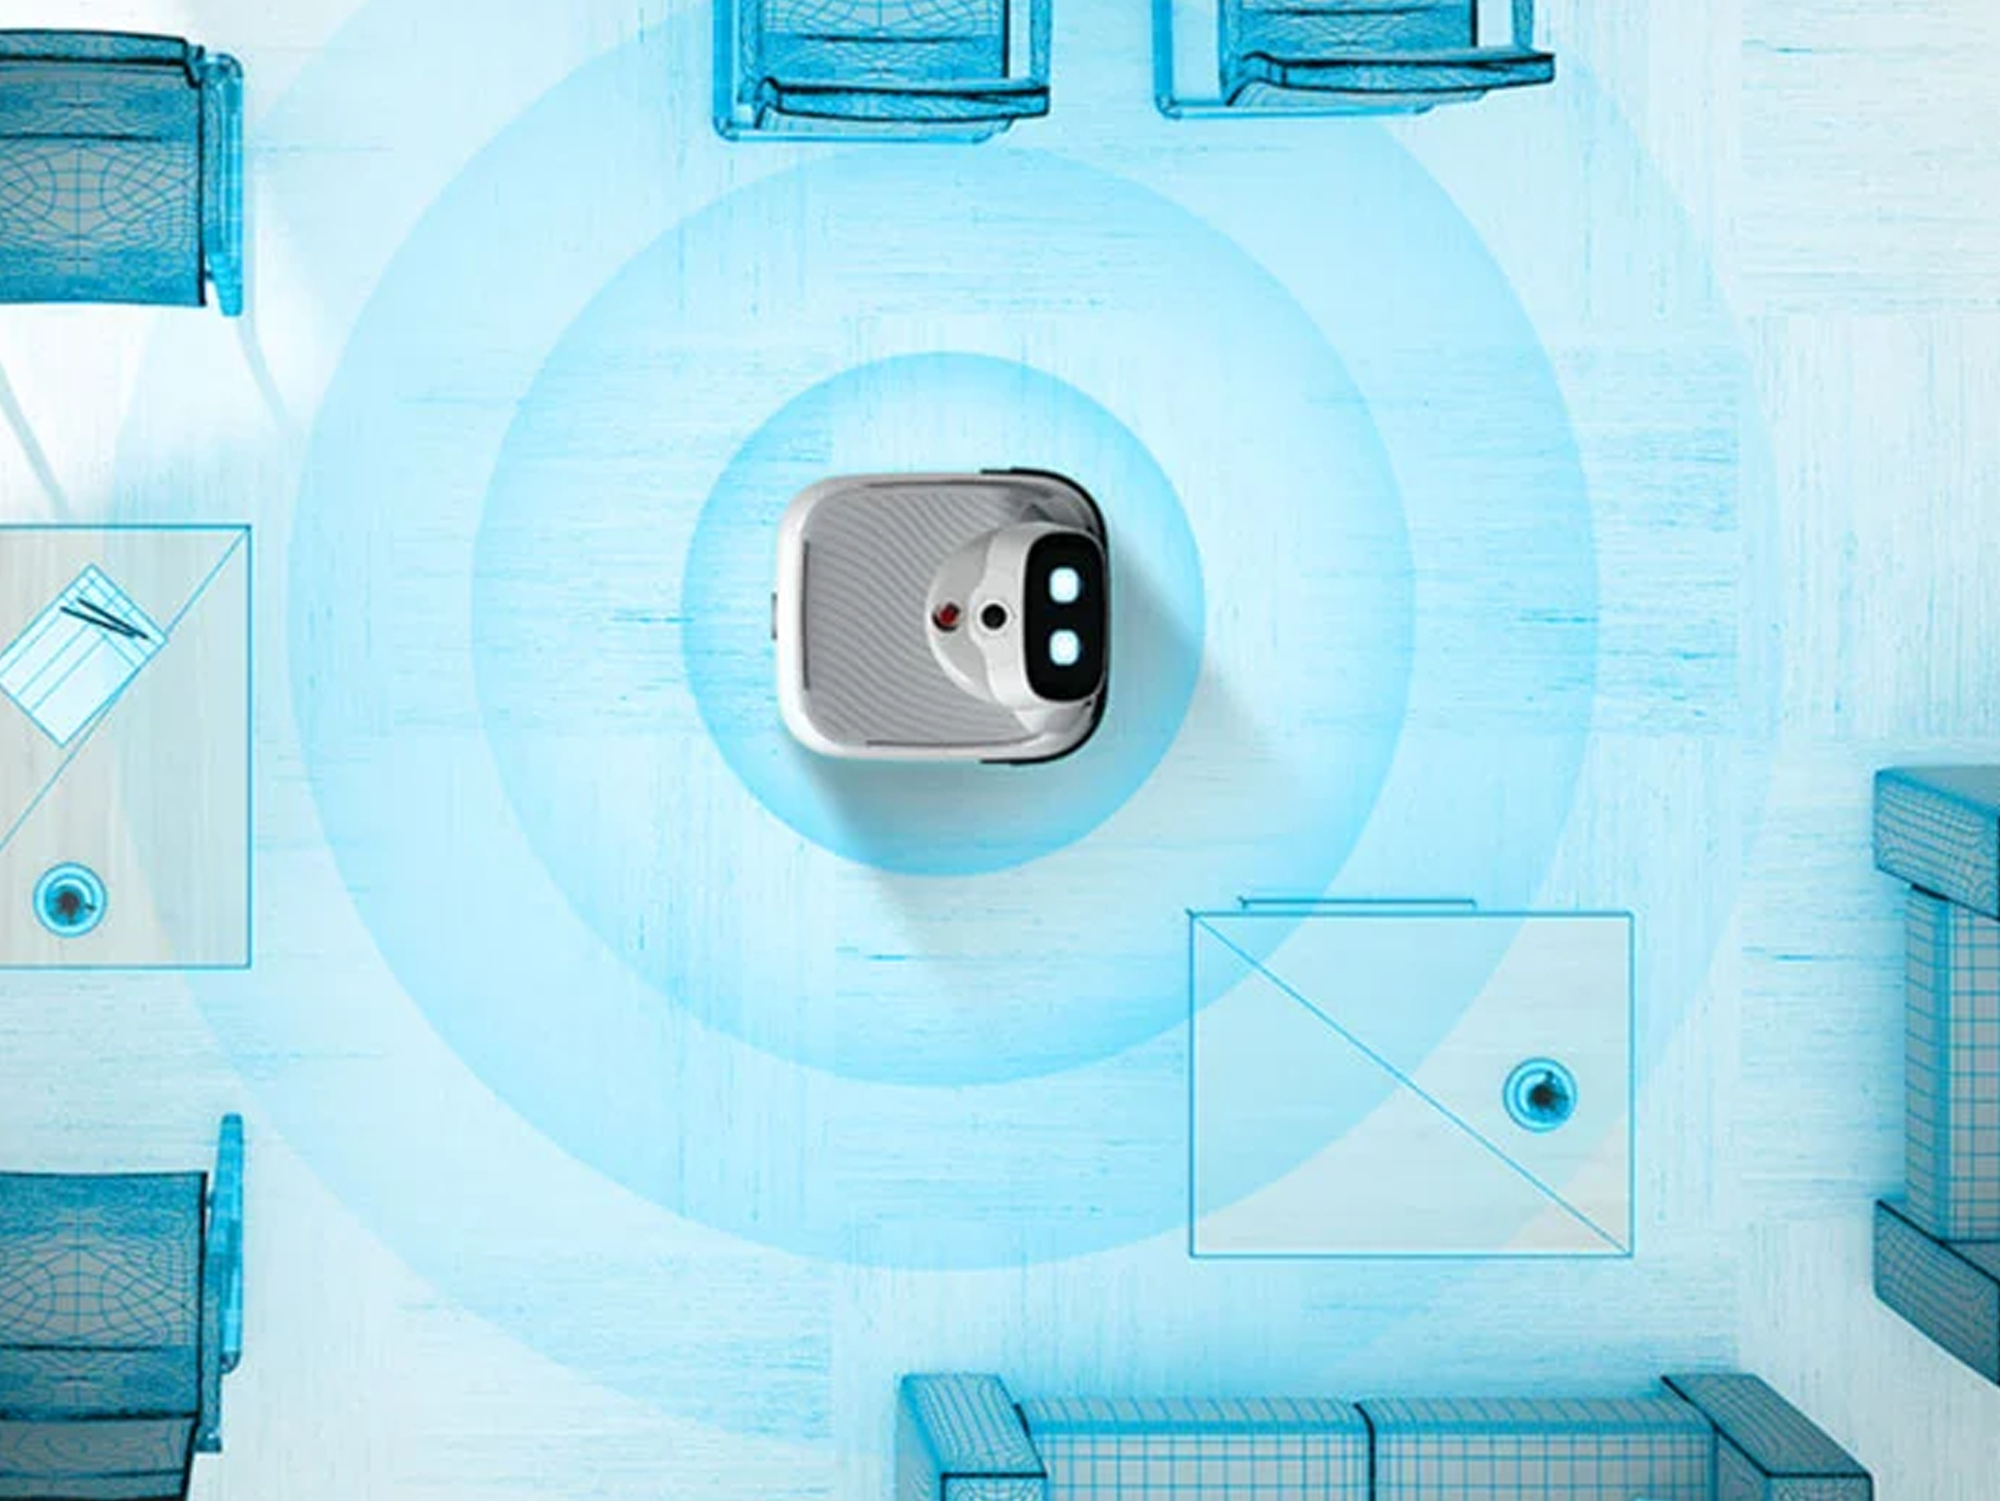
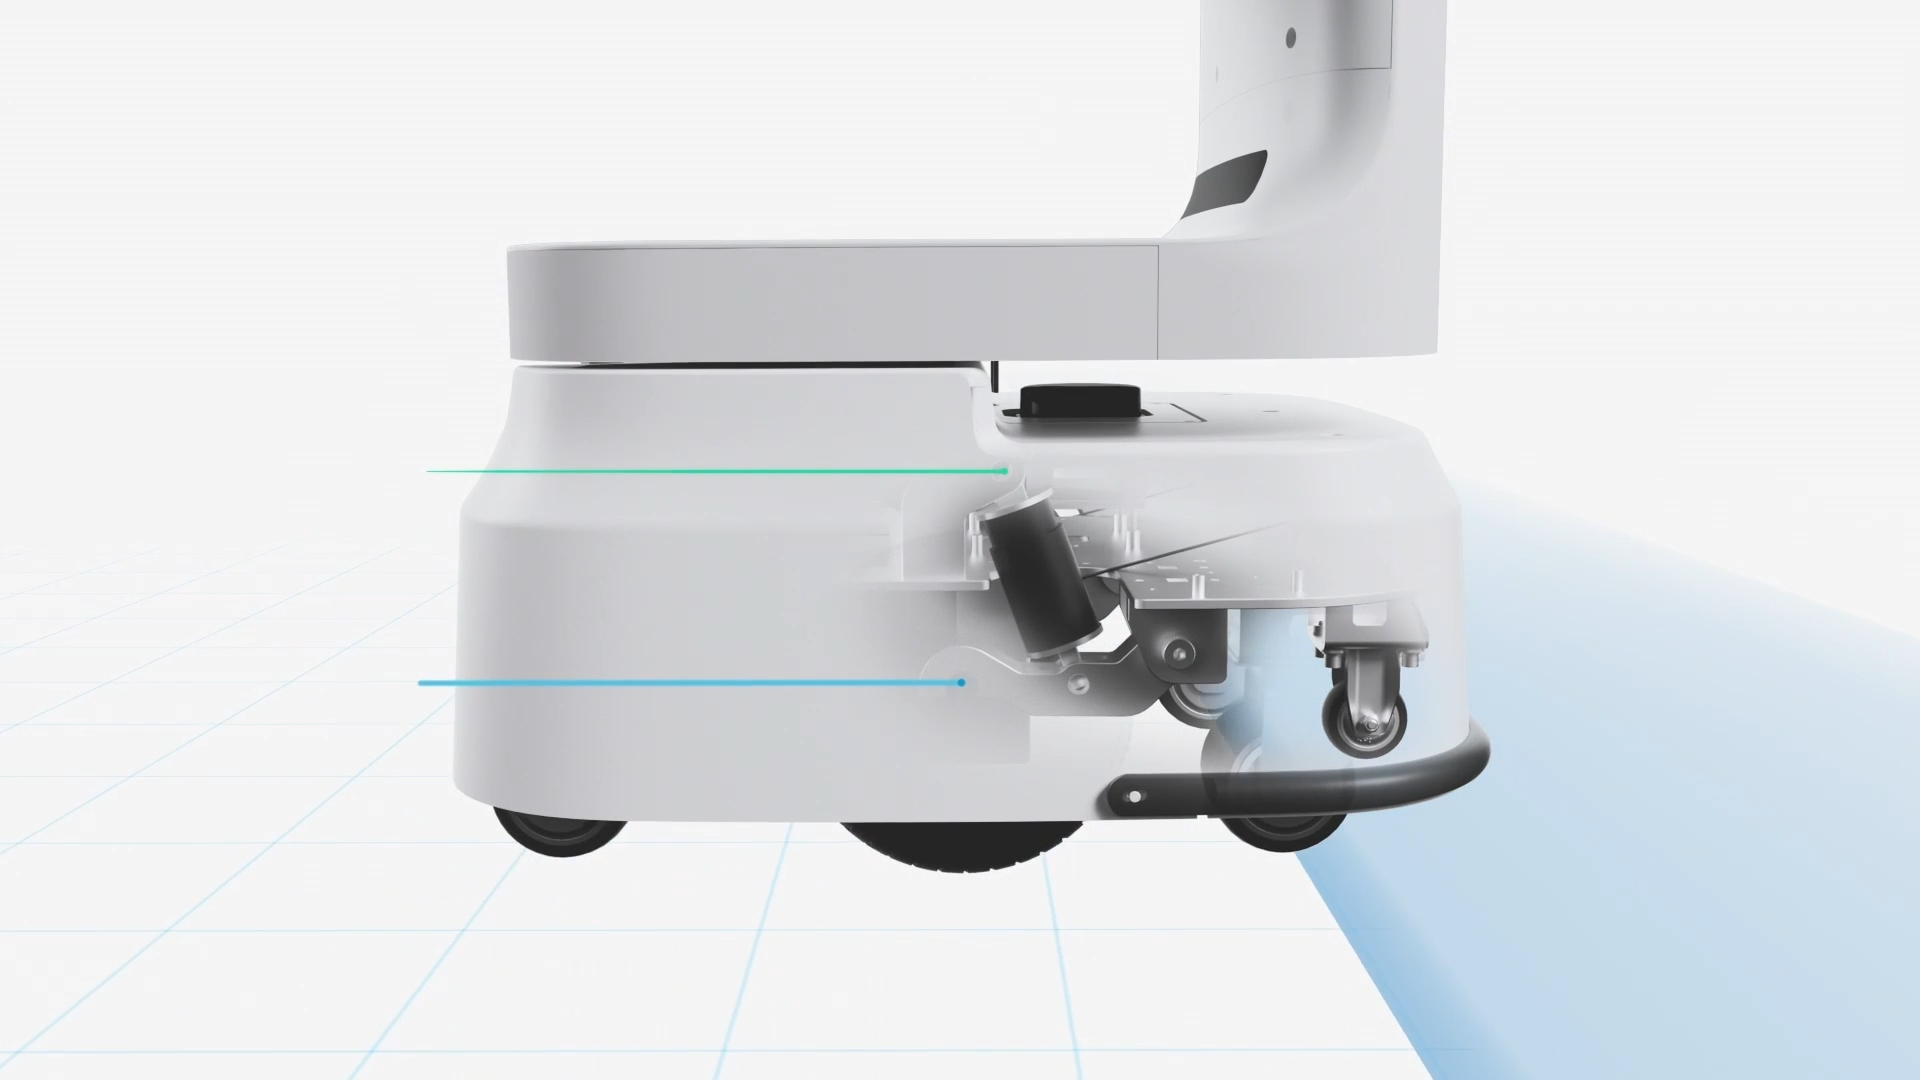
RGBD depth cameras, lidar and ultrasonic layers fuse into one occupancy picture, people, chair legs, glass and 5 cm thresholds, read at up to 30 m.
A fused occupancy picture
RGBD depth cameras, lidar and ultrasonic sensors publish into one model of the world: people, chair legs, glass doors, 5 cm thresholds and 30 m of forward radar coverage. No single sensor is trusted alone. Glass reads in ultrasound, dark floors read in vision, crowds read in lidar.
Human intent, not just human position
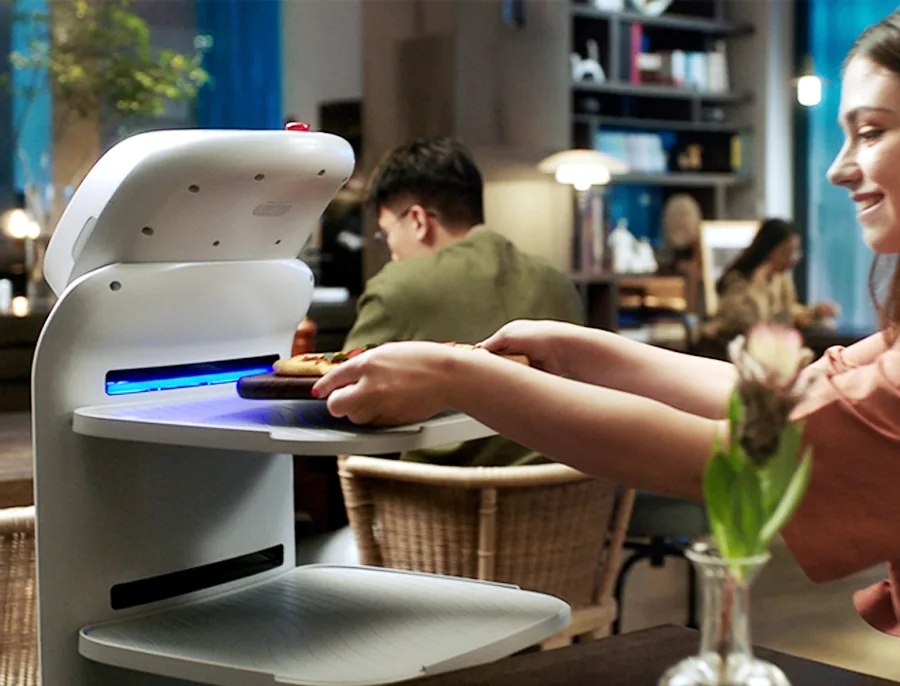
Depth cameras classify motion, not just distance: a person walking toward the robot reads differently from a person standing in conversation. Delivery robots slow, announce with light and voice, and re-plan, instead of braking mid-corridor.
The same stack in every chassis
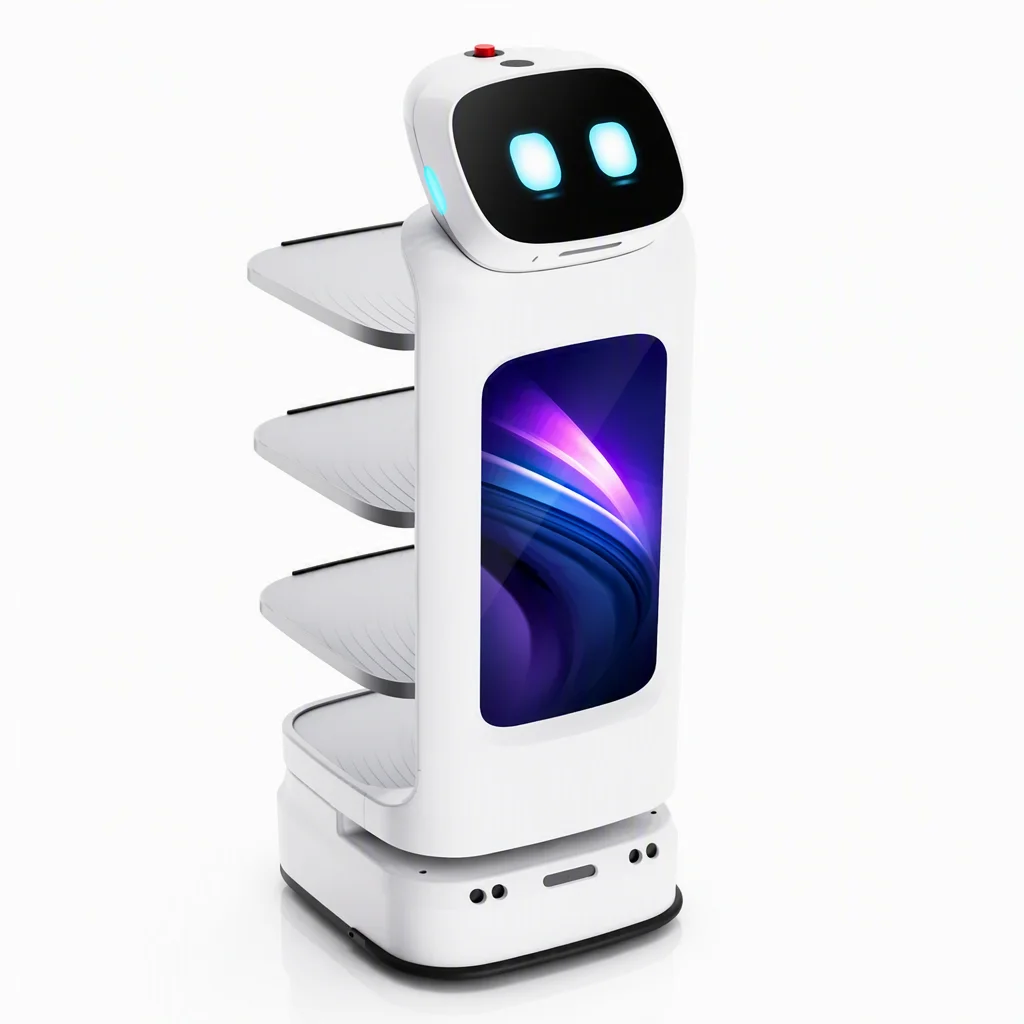
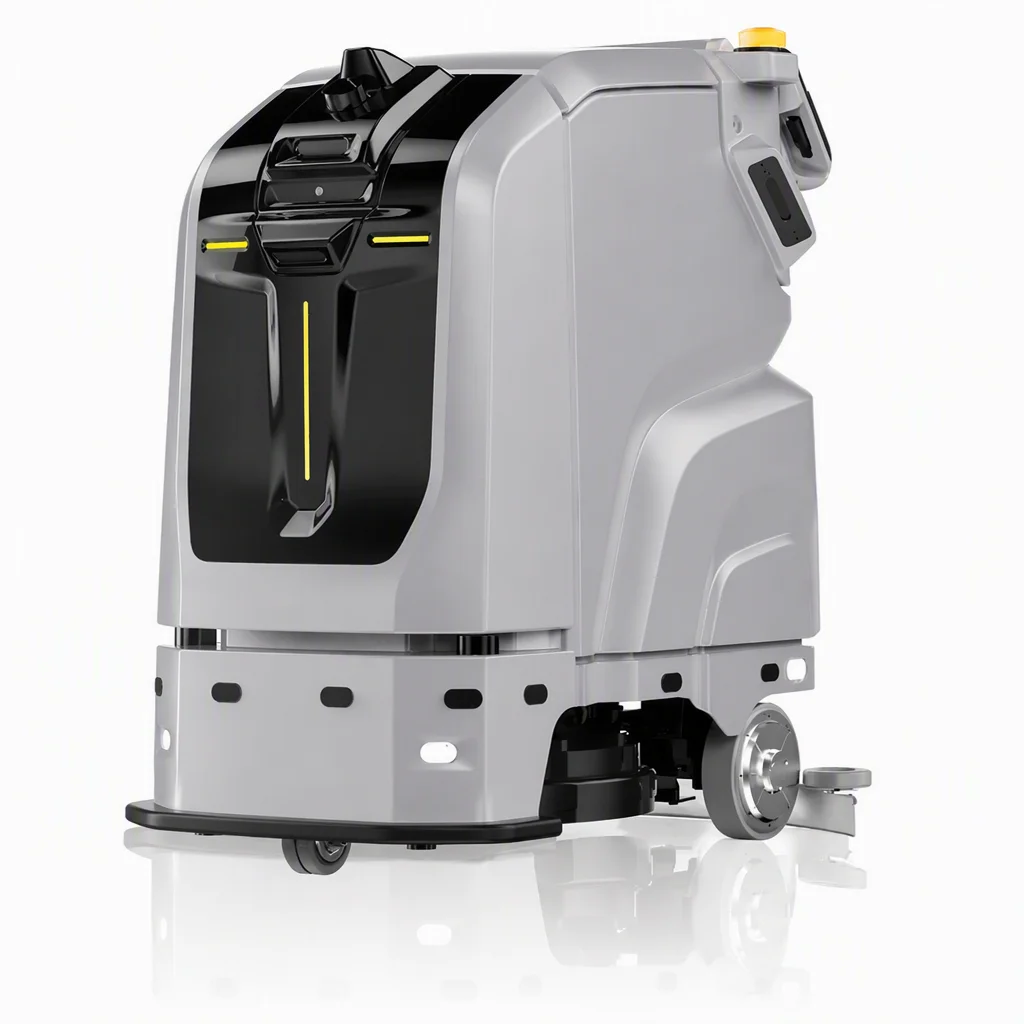
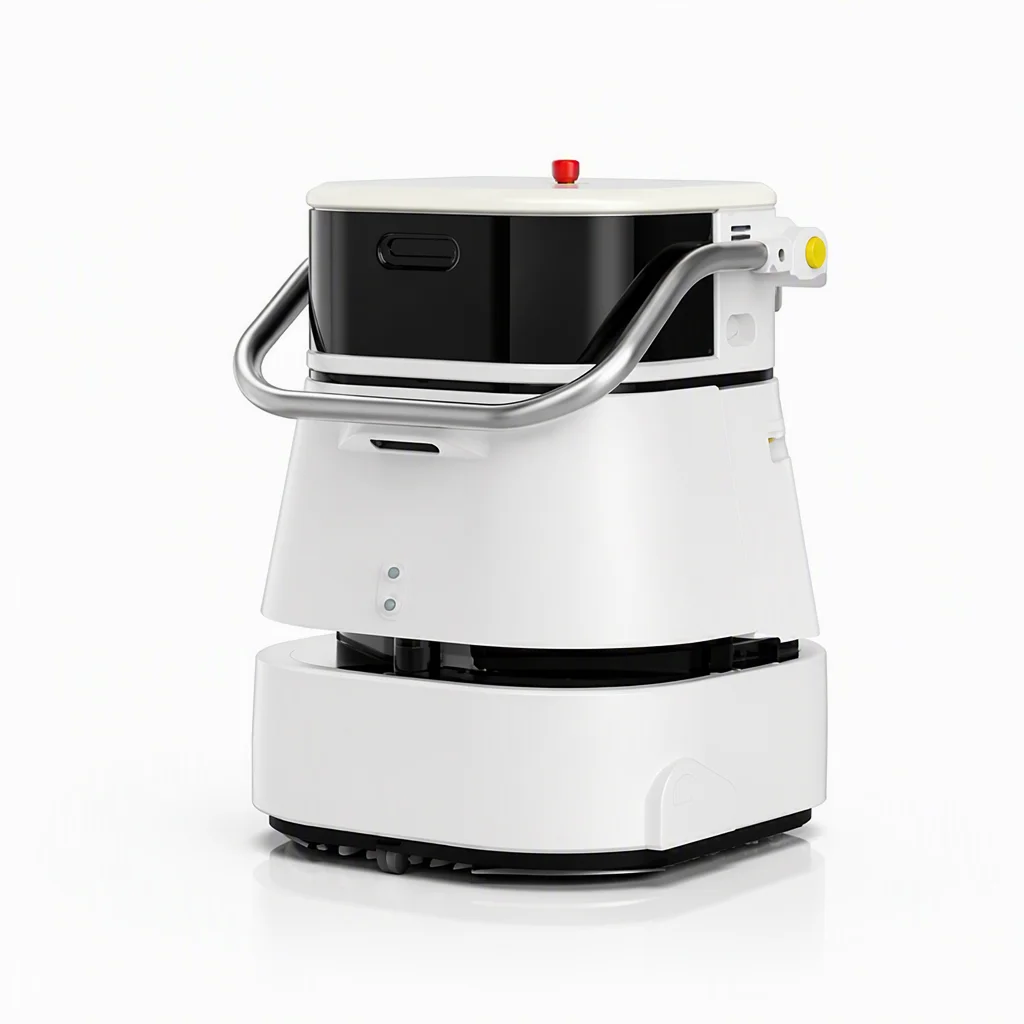
Perception is one platform across D1, C1, C2 Pro and G1. A lesson learned on a scrubber's night program ships to every fleet in the next release. Which is why mixed fleets get safer, not more complicated, over time.
Talk to an engineer
Integration questions answered by the people who ship the stack.